Visit my github for more code.
 Reinforcement Learning
wheeled-legged locomotion
Robust locomotion with RL for wheeled-legged robots.
Website ↗ Reinforcement Learning
racing-dreamer
Model-based RL for autonomous racing trained on latent imagination learned from high-dimensional LiDAR data.
Code ↗ Reinforcement Learning
racecar-gym
A gym environment for a miniature, F1Tenth-like racecar using the bullet physics engine with pybullet.
Code ↗ Reinforcement Learning
auto-shaping
Specification-based library for automatic reward shaping.
Code ↗ Reinforcement Learning
agency-preserving-rl
Training an altruistic agent under partially-observable, evolving and under-represented goals.
Code ↗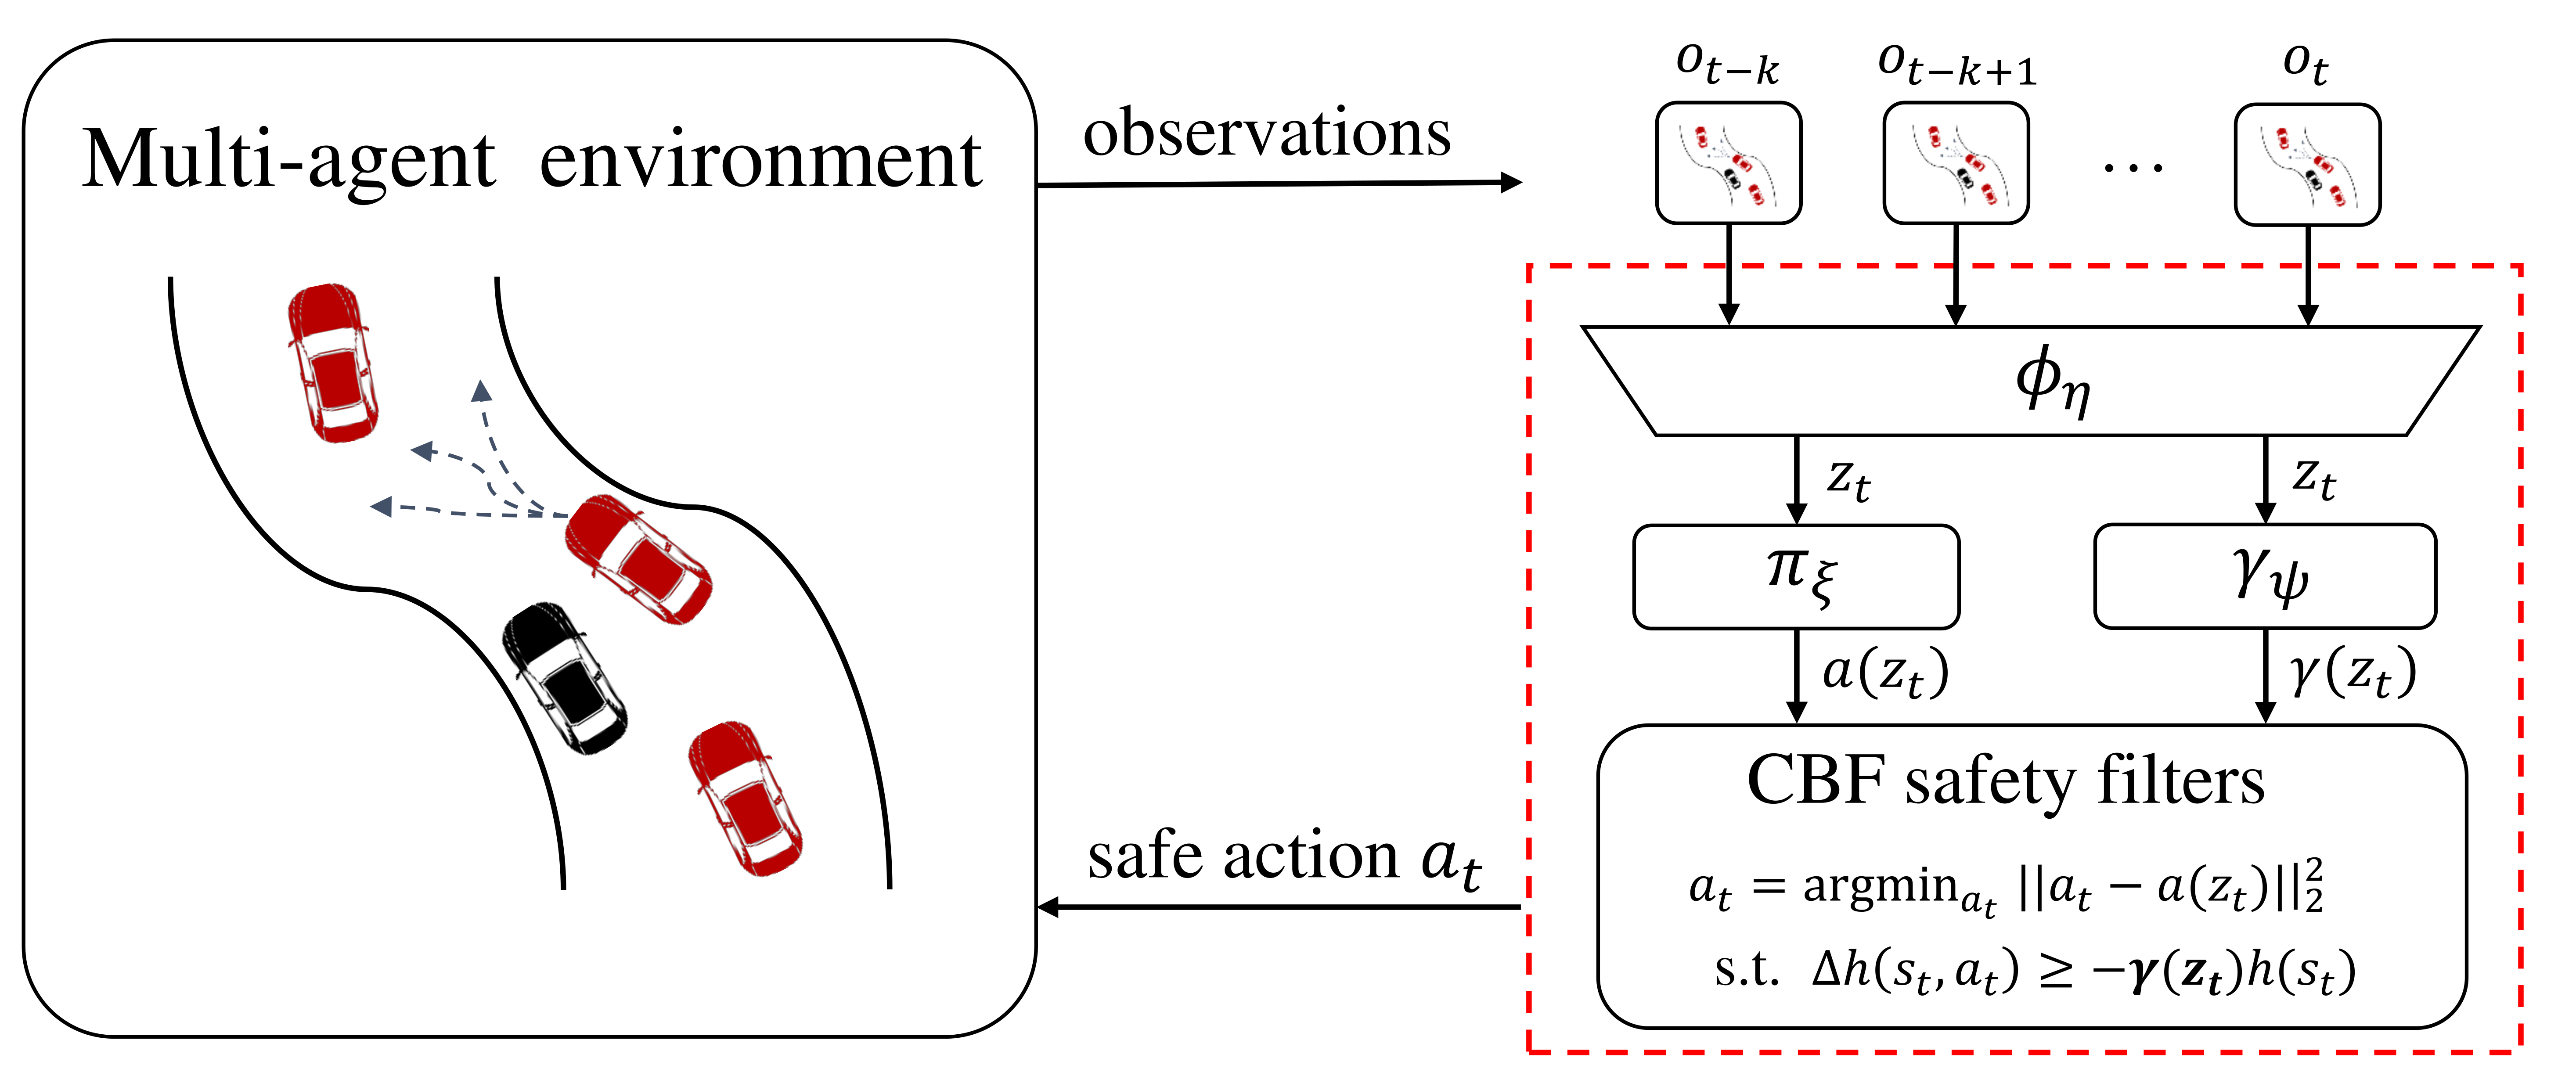 Reinforcement Learning
learning-adaptive-safety
Learning adaptive safety for multi-agent systems with RL and control barrier functions.
Code ↗ Robotics
mobile-robotics-ros
Self-localization, mapping and motion planning for a differential drive robot using ROS.
Code ↗ Robotics
f110-rl-ros
Deployment of reinforcement learning agents on the F1Tenth platform using ROS.
Code ↗ Formal Methods
fosco
Learner-Verifier framework for formal synthesis of Control Barrier Function.
Code ↗